|
Jinwoo Choi Hi! I'm a Ph.D. student in the Department of Electrical and Computer Engineering at Seoul National University, advised by Prof. Seung-Woo Seo and affiliated with the Vehicle Intelligence Lab. My research focuses on developing reinforcement learning algorithms for long-horizon decision-making. In particular, my goal is to enable agents to learn useful behavioral abstractions and make effective decisions toward distant goals. I also have experience in robotic exploration and autonomous-driving planning, including real-world testing with robotic and vehicle systems. Building on these experiences, I am interested in extending reinforcement learning methods to complex decision-making problems in robotics. |
|
Publications |
|
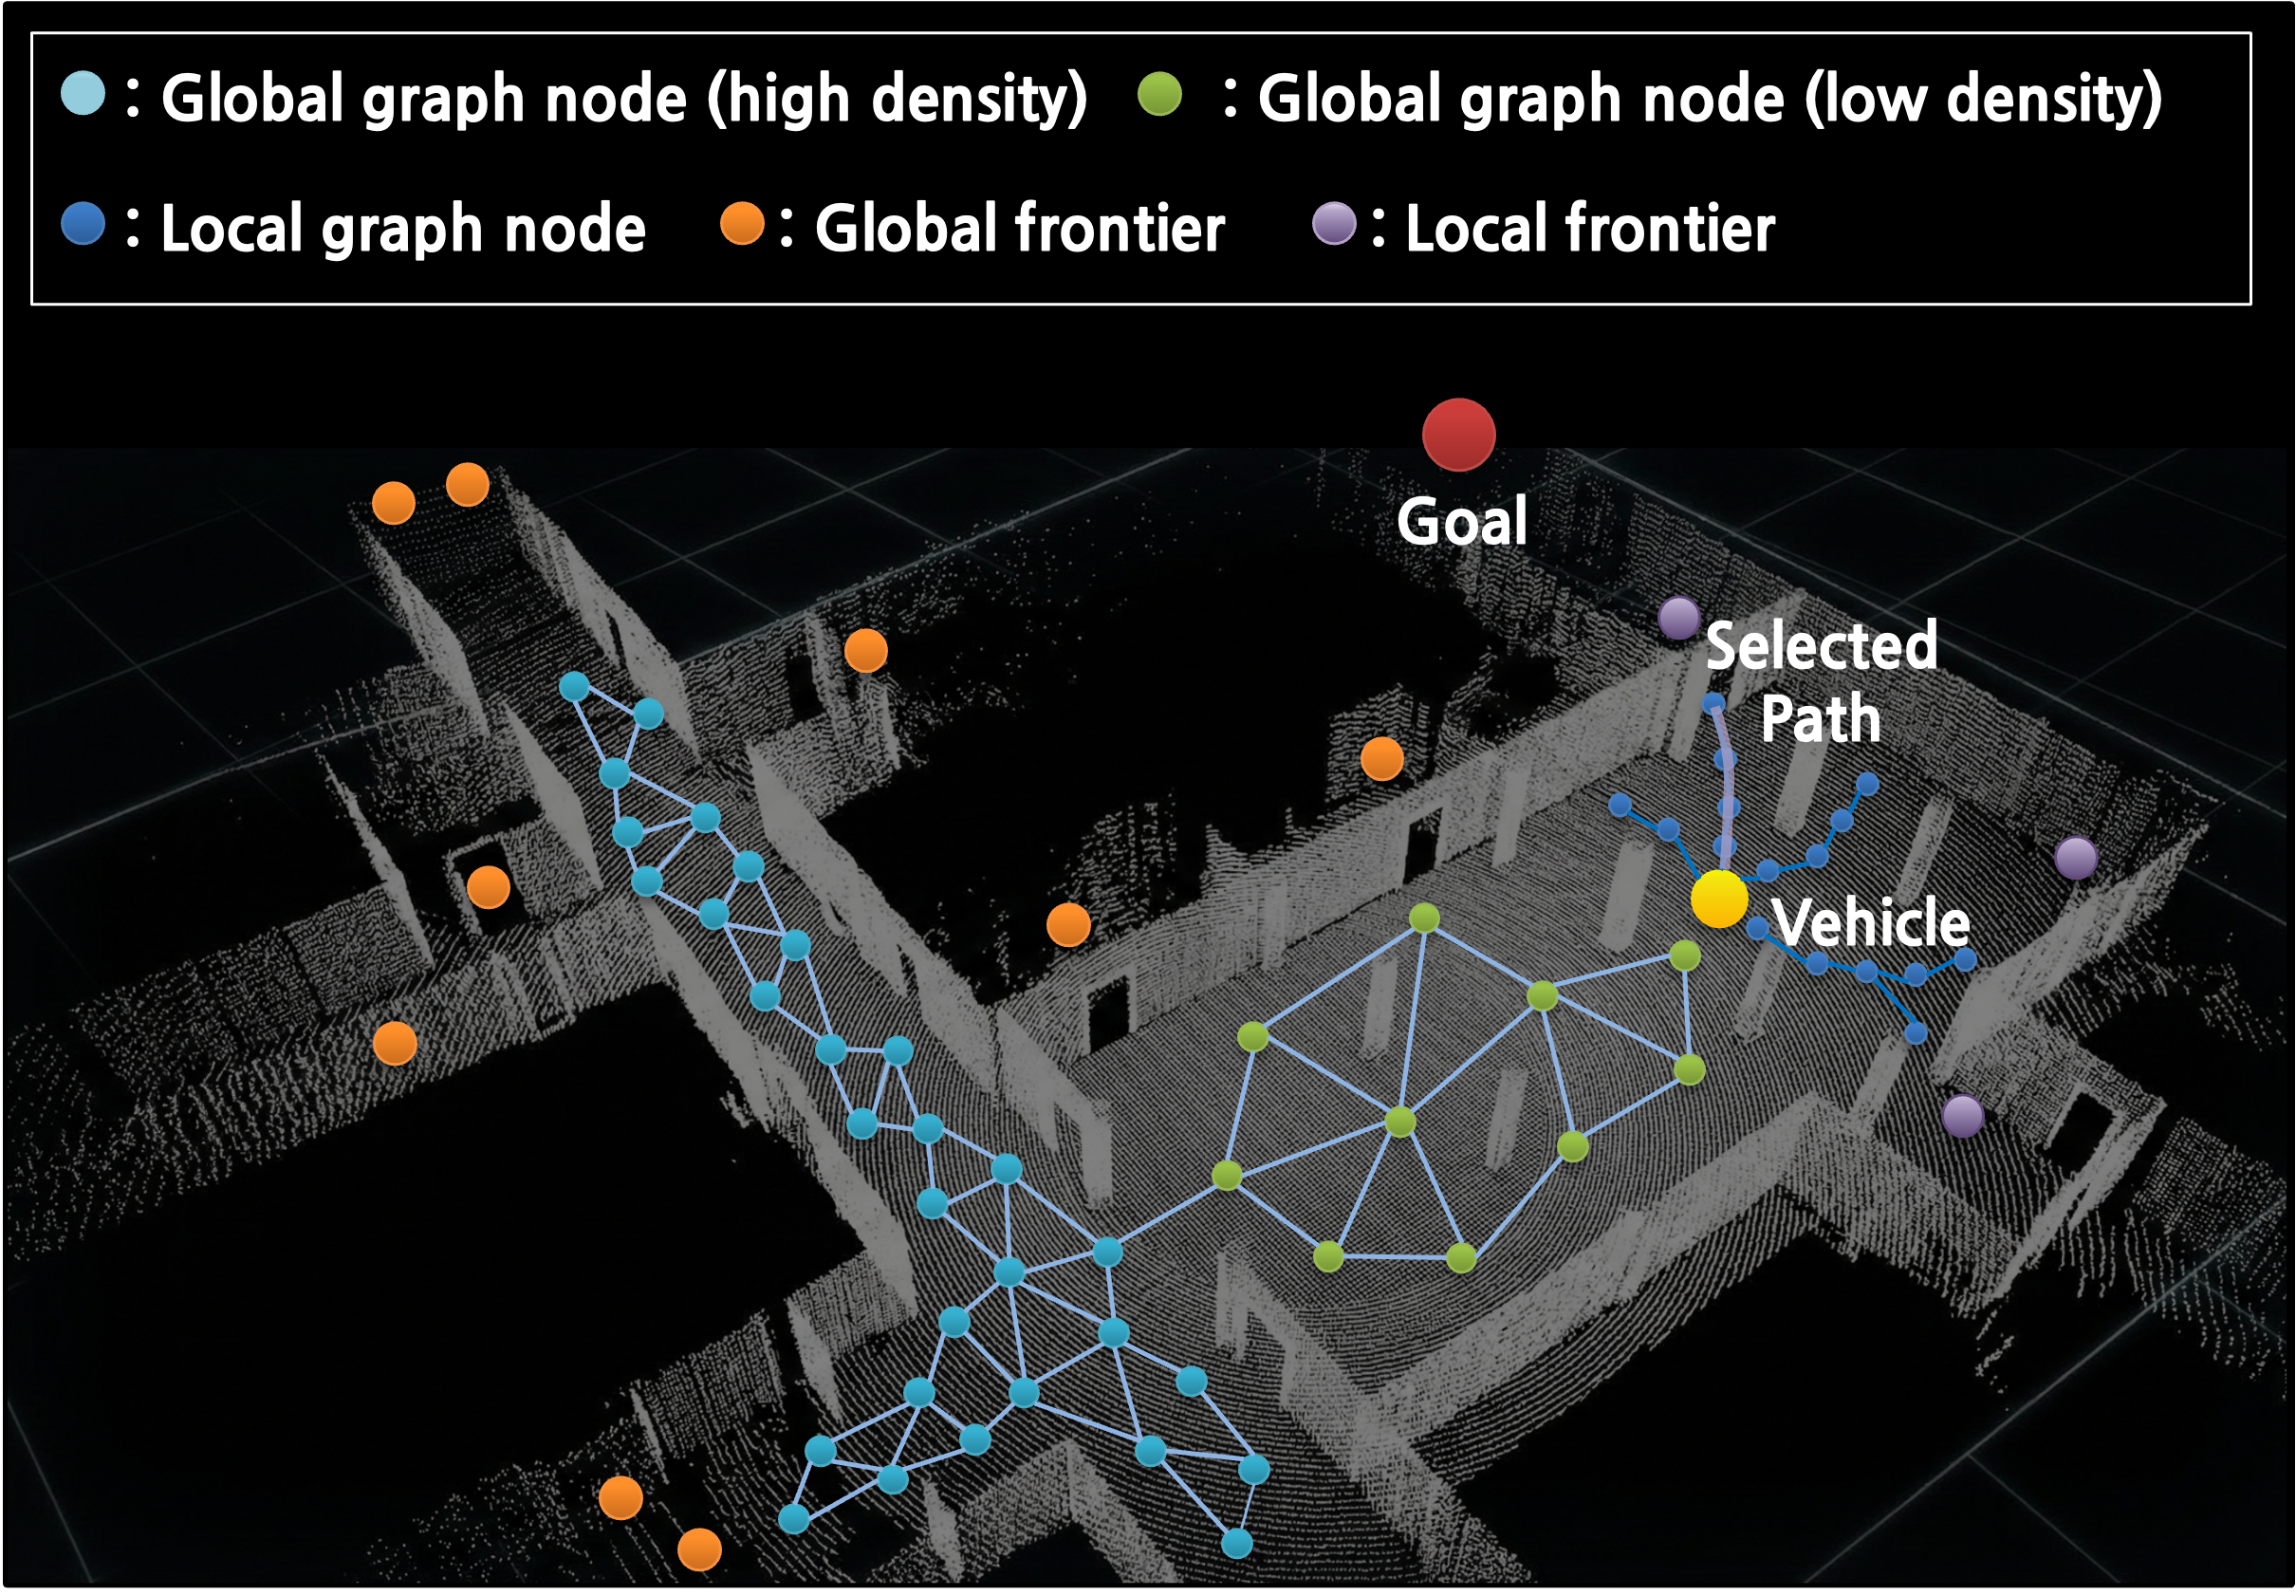
FPAS: Frontier-Based Path Planning with Adaptive Sampling for Large-Scale Unknown Environments
IROS, 2026
|
|
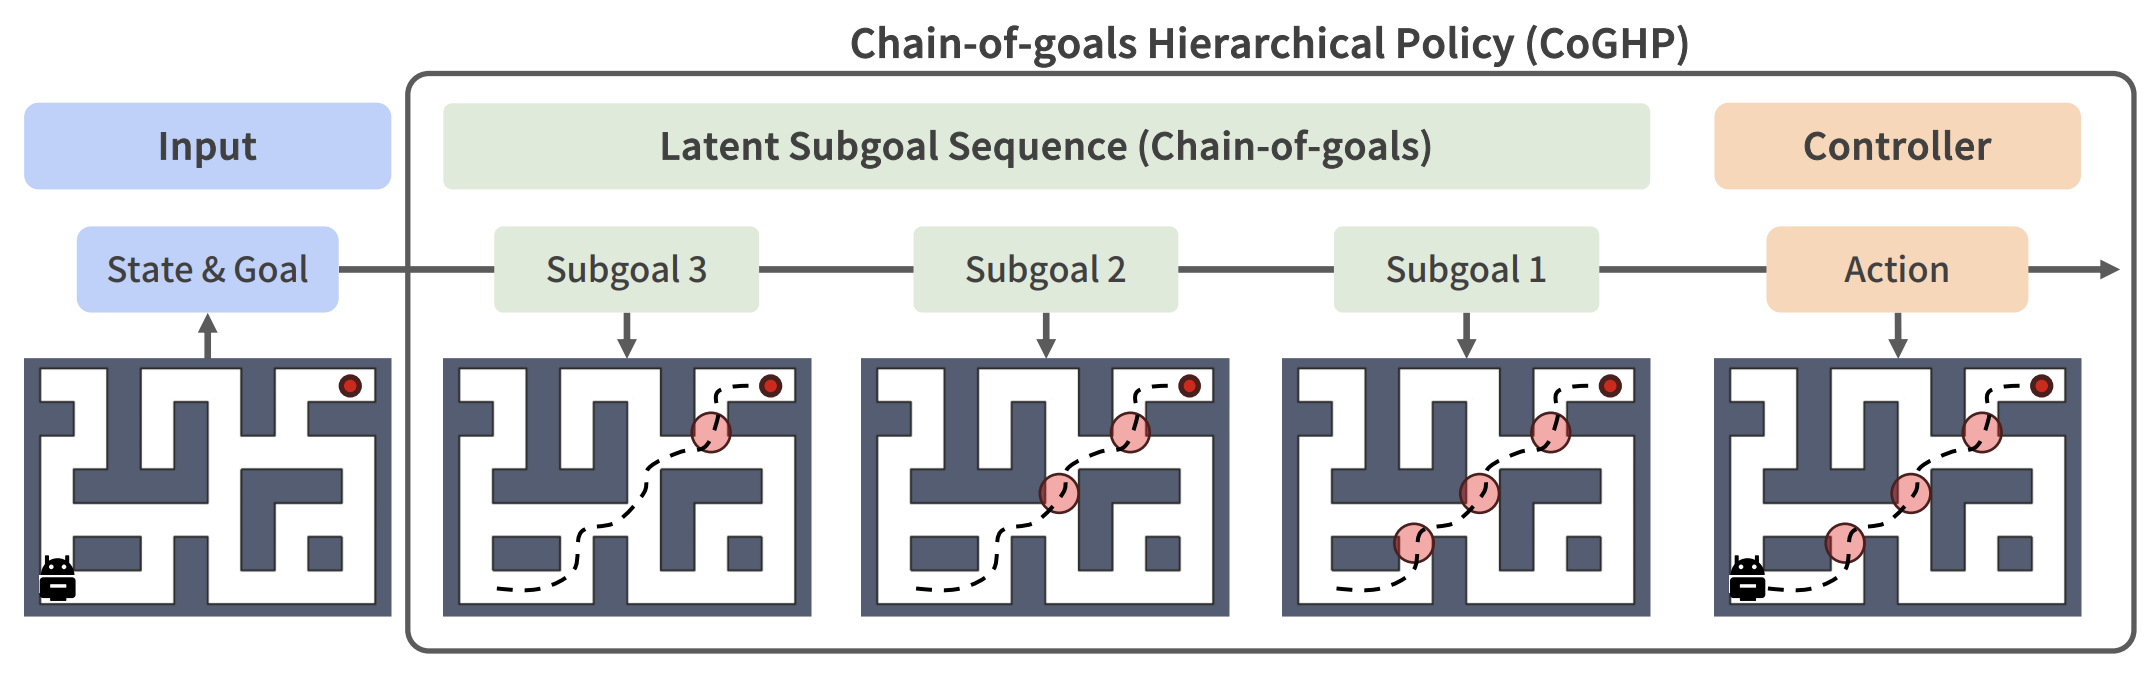
Chain-of-Goals Hierarchical Policy for Long-Horizon Offline Goal-Conditioned RL
ICML, 2026
|
|
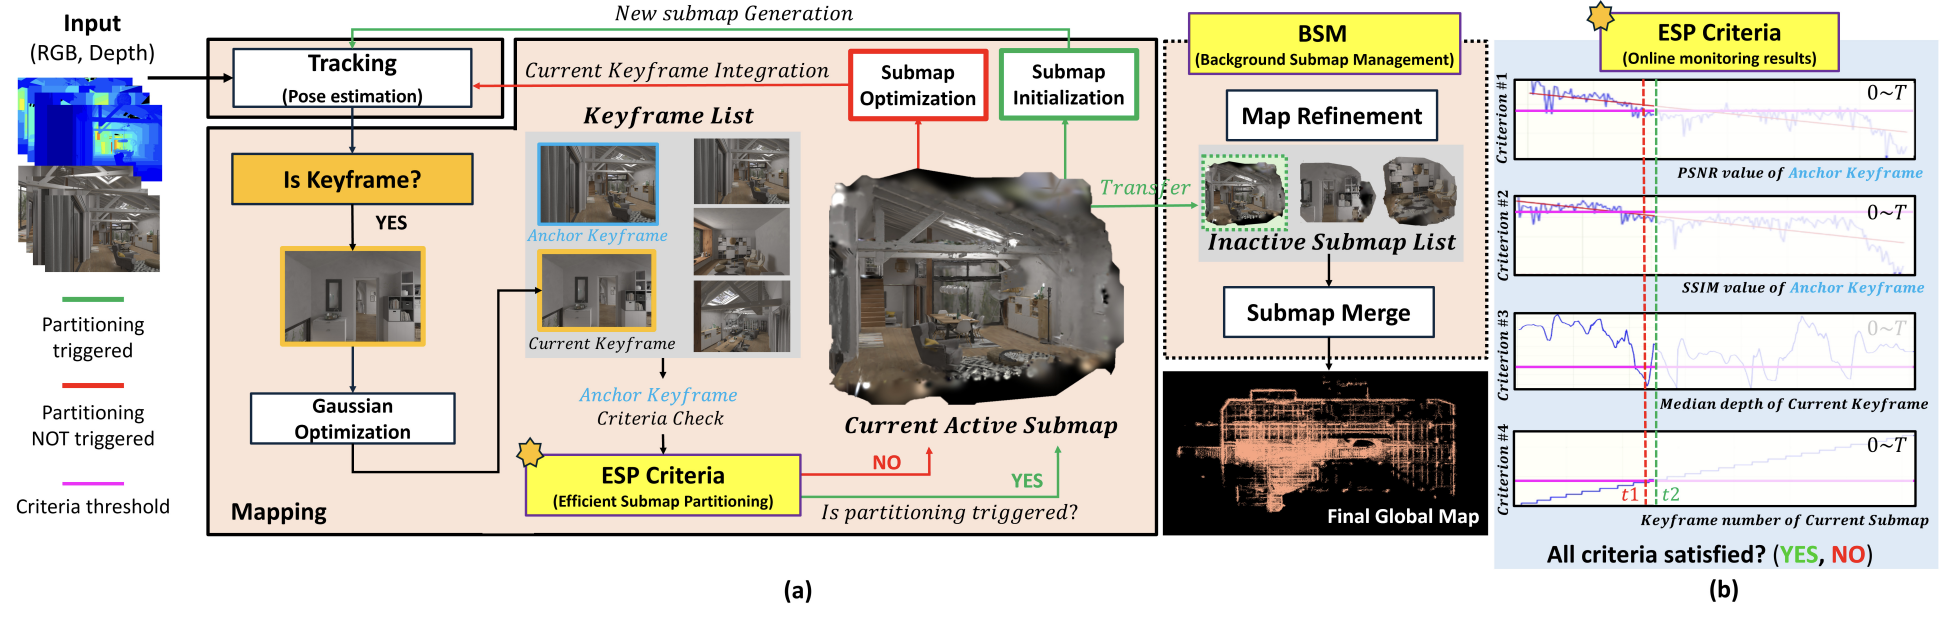
ESP-SLAM: Efficient Submap Partitioning for Large-Scale 3D Gaussian Splatting-Based SLAM
IEEE Robotics and Automation Letters (RA-L), 2026
|
|
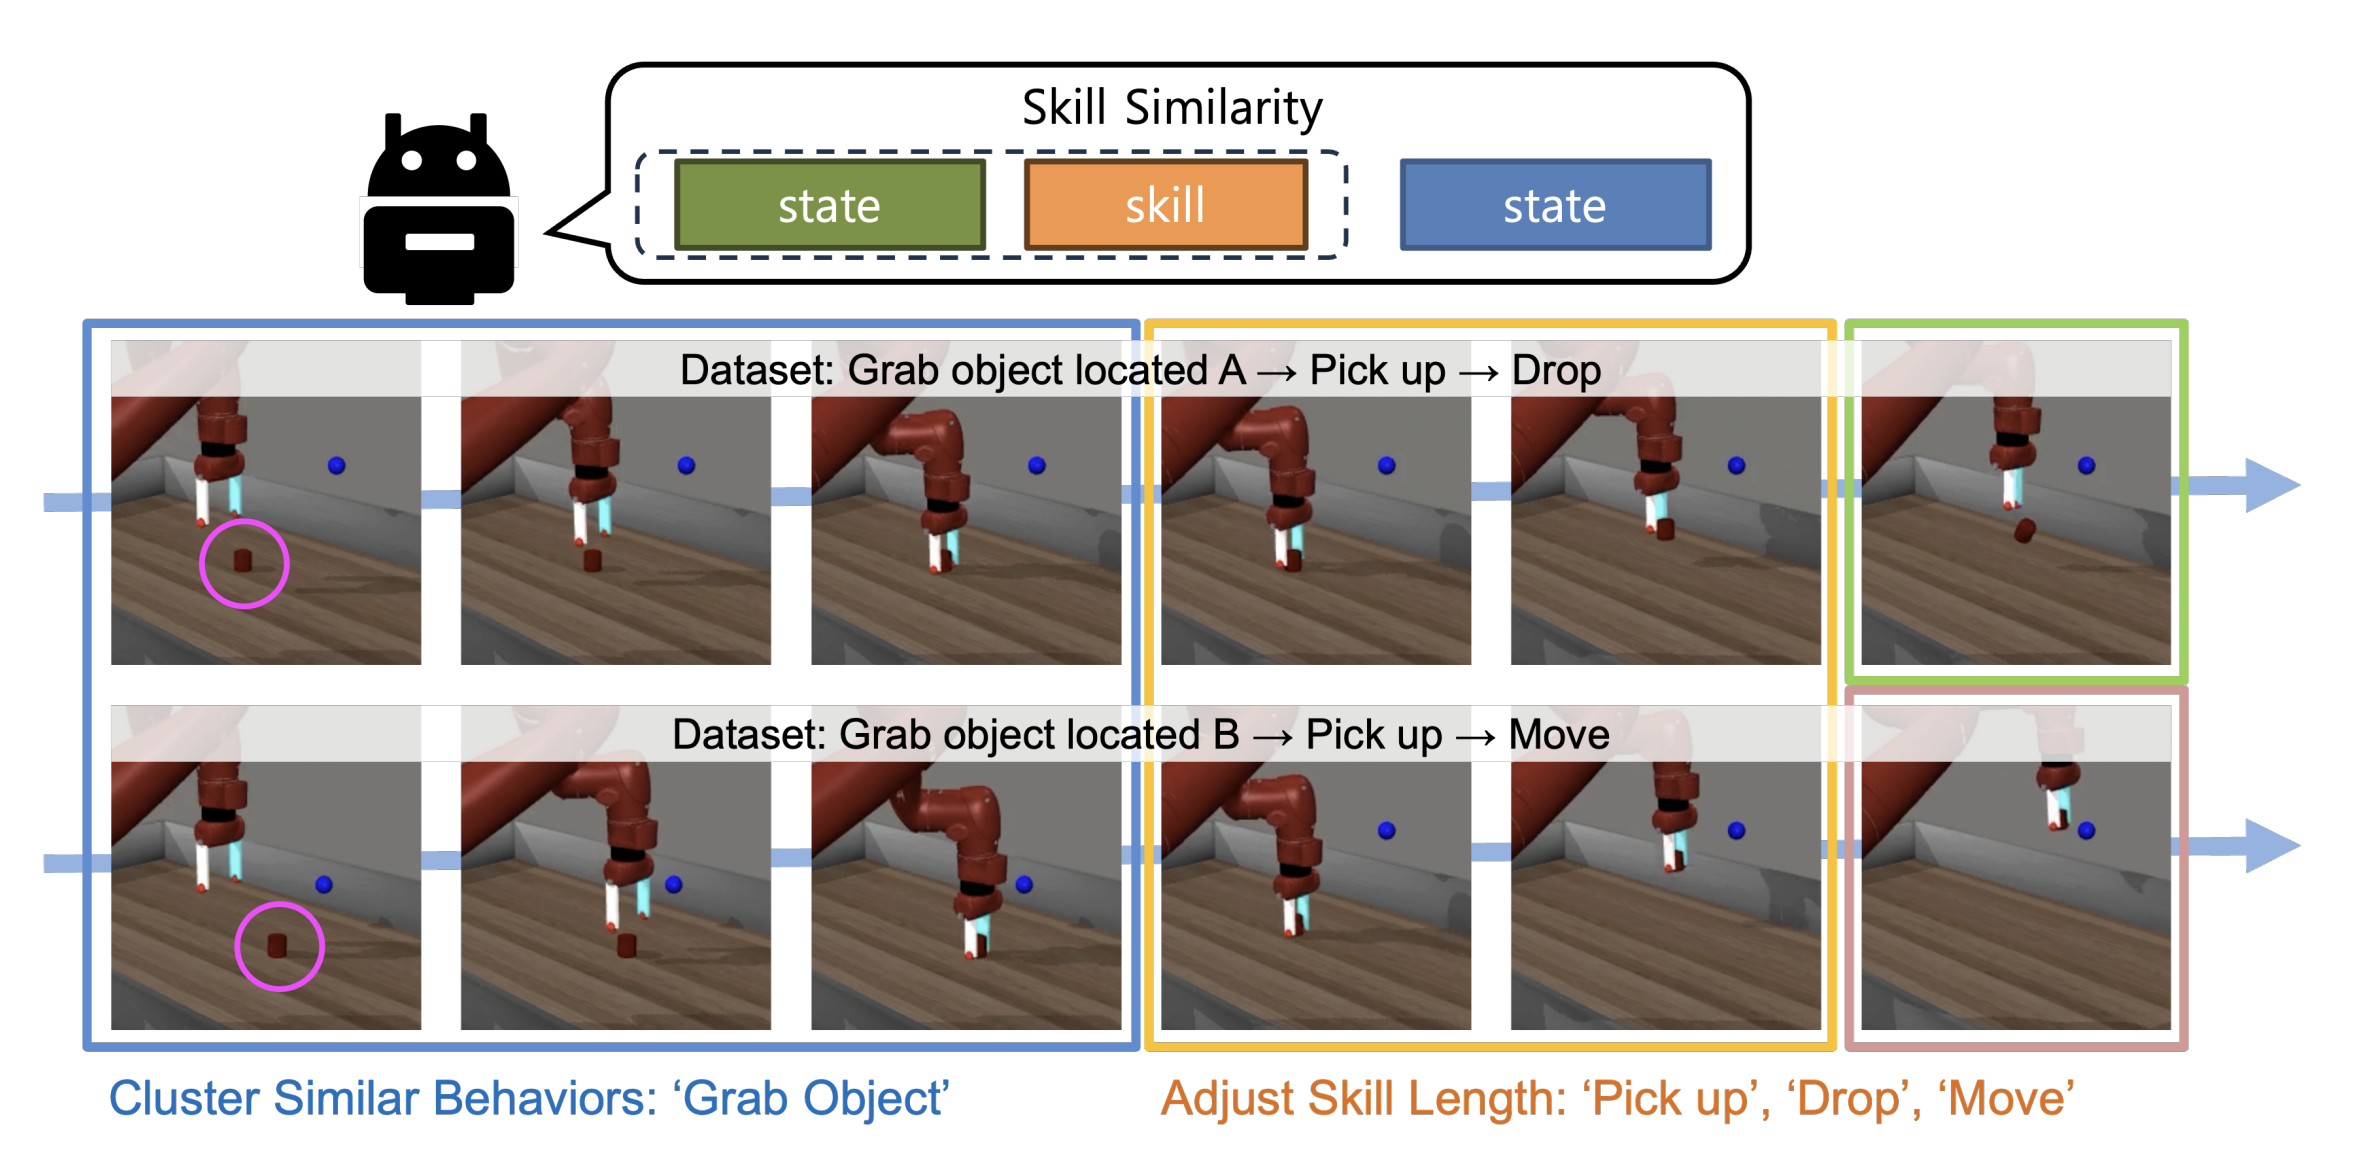
Dynamic Contrastive Skill Learning with State-Transition Based Skill Clustering and Dynamic Length Adjustment
ICLR, 2025
|
|
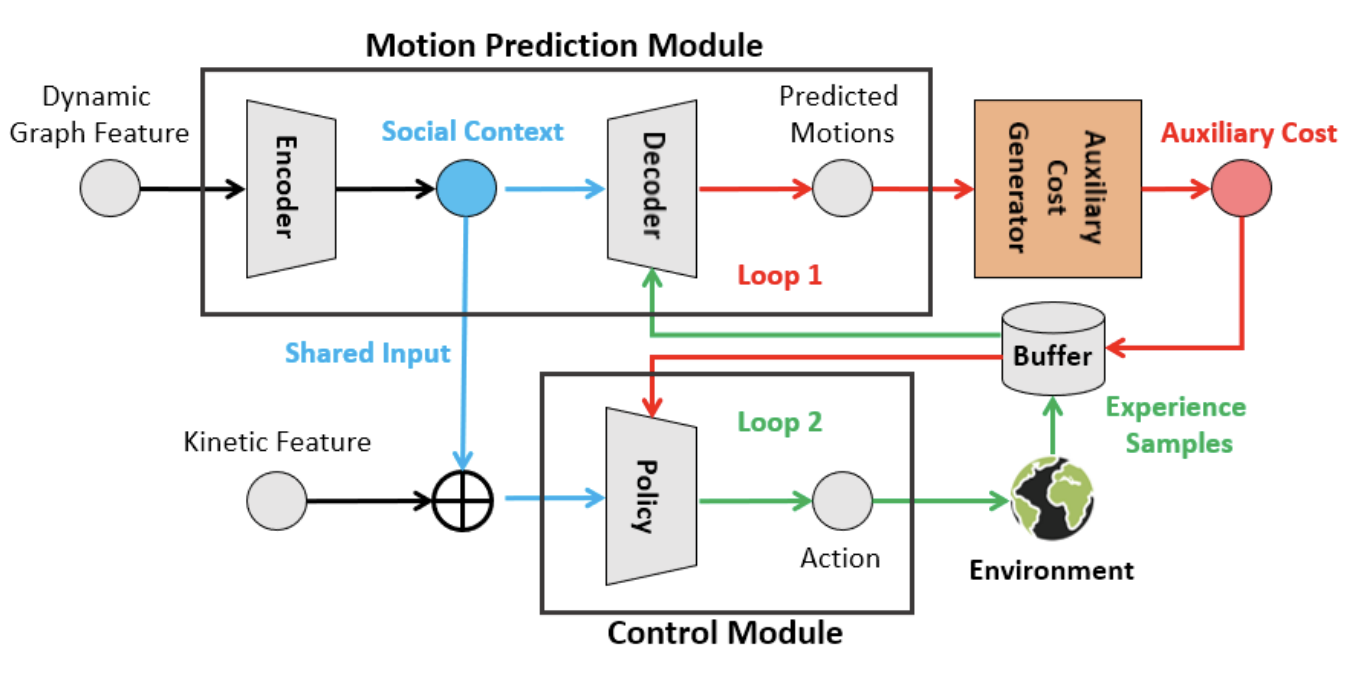
GIN: Graph-based interaction-aware constraint policy optimization for autonomous driving
IEEE Robotics and Automation Letters (RA-L), 2022
|
|
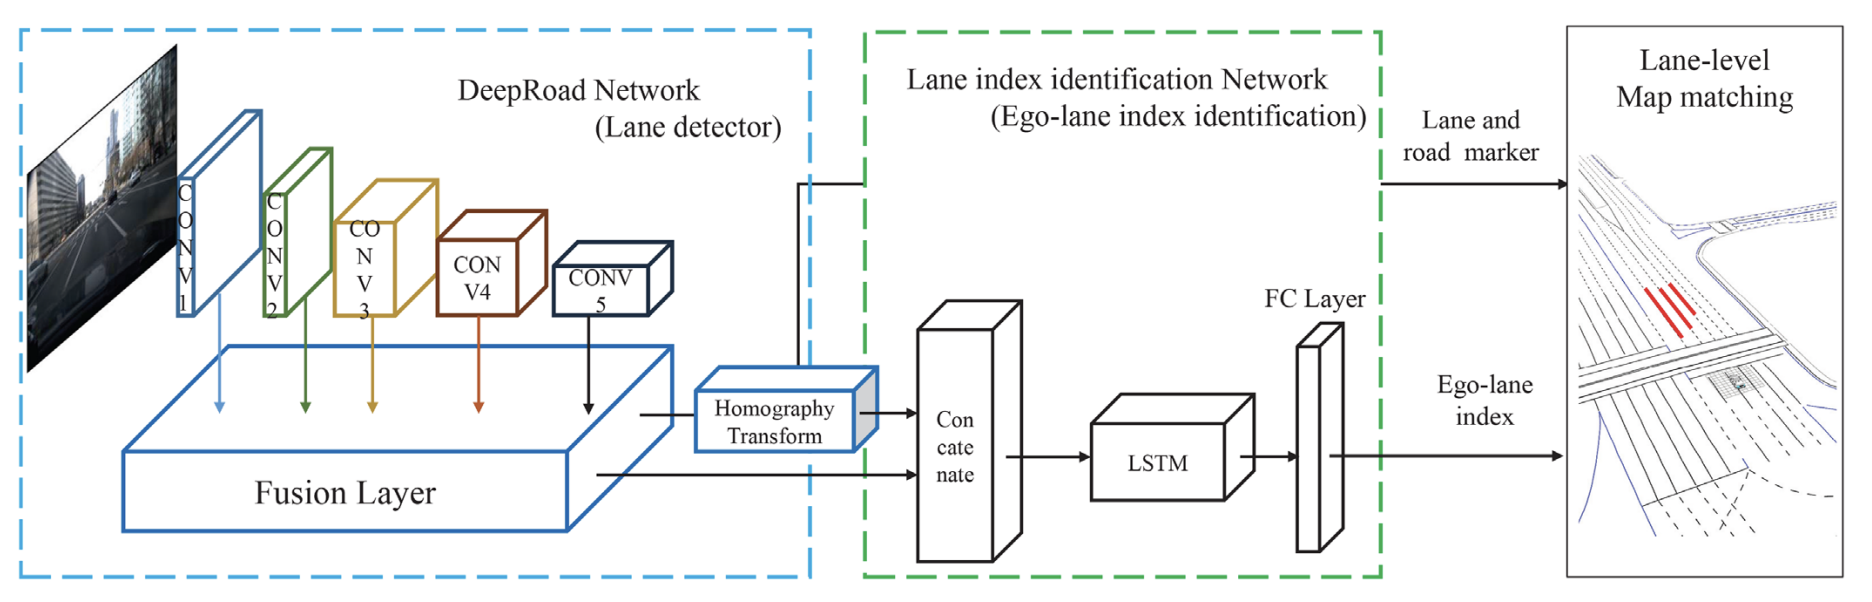
Ego‐lane index‐aware vehicular localisation using the DeepRoad Network for urban environments
IET Intelligent Transport Systems, 2021
|
Selected ProjectsHover over an image to play the video. On mobile, tap an image. |
|
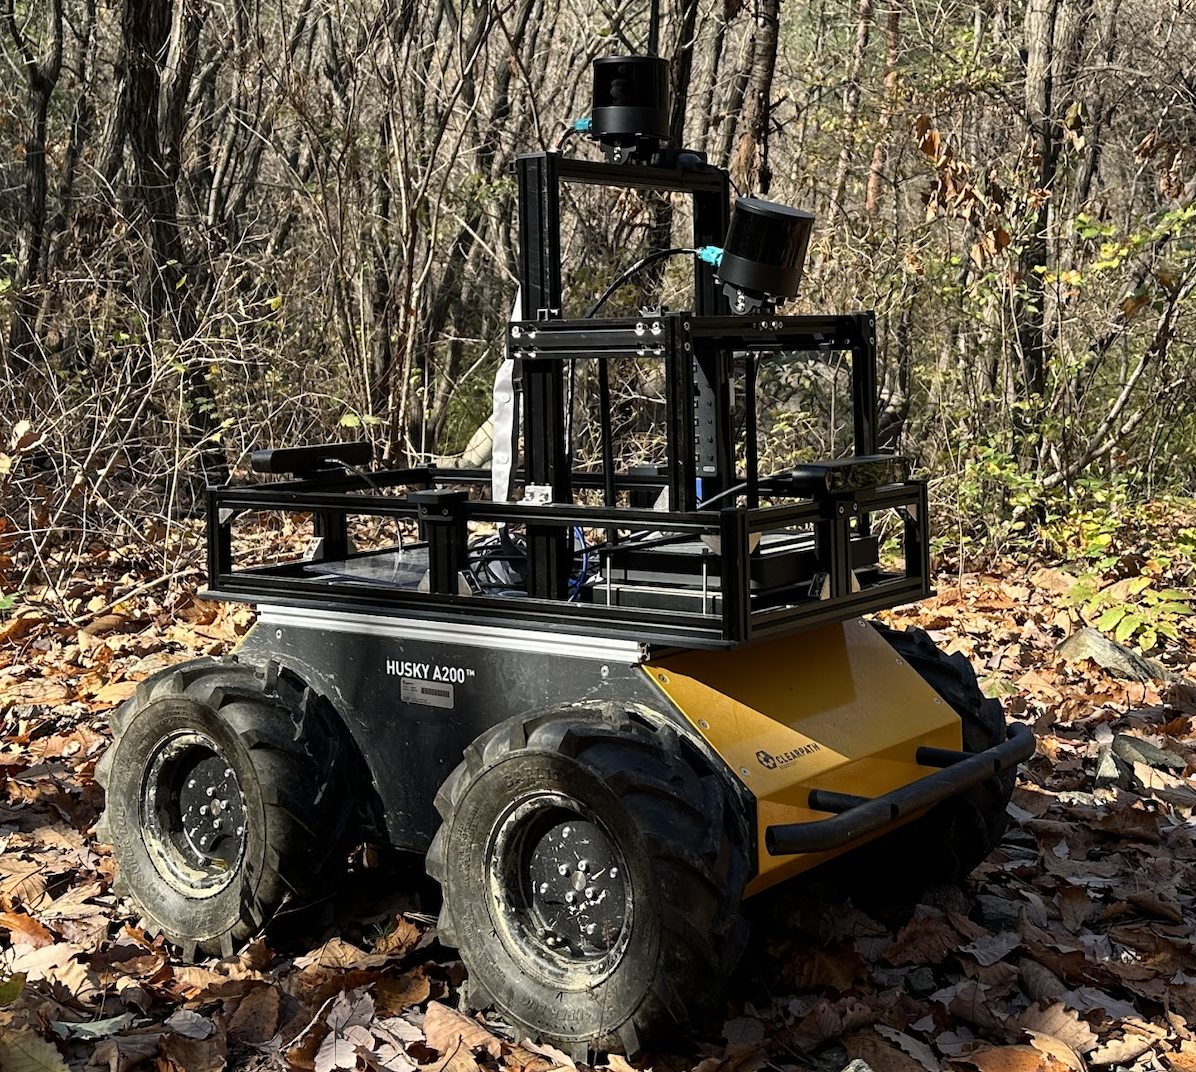
VISKY: Mobile Robot for Autonomous Exploration in Unstructured Environments
Jan 2022 – Present
VISKY is a mobile robot developed for autonomous exploration in unknown and unstructured environments as part of an ADD-funded research project. I served as Project Manager for the overall project (January 2022 – June 2023) and led global path planning research (FPAS, IROS 2026). I also participated in real-world testing of the autonomous exploration system using a Clearpath Husky-based mobile robot. |
|
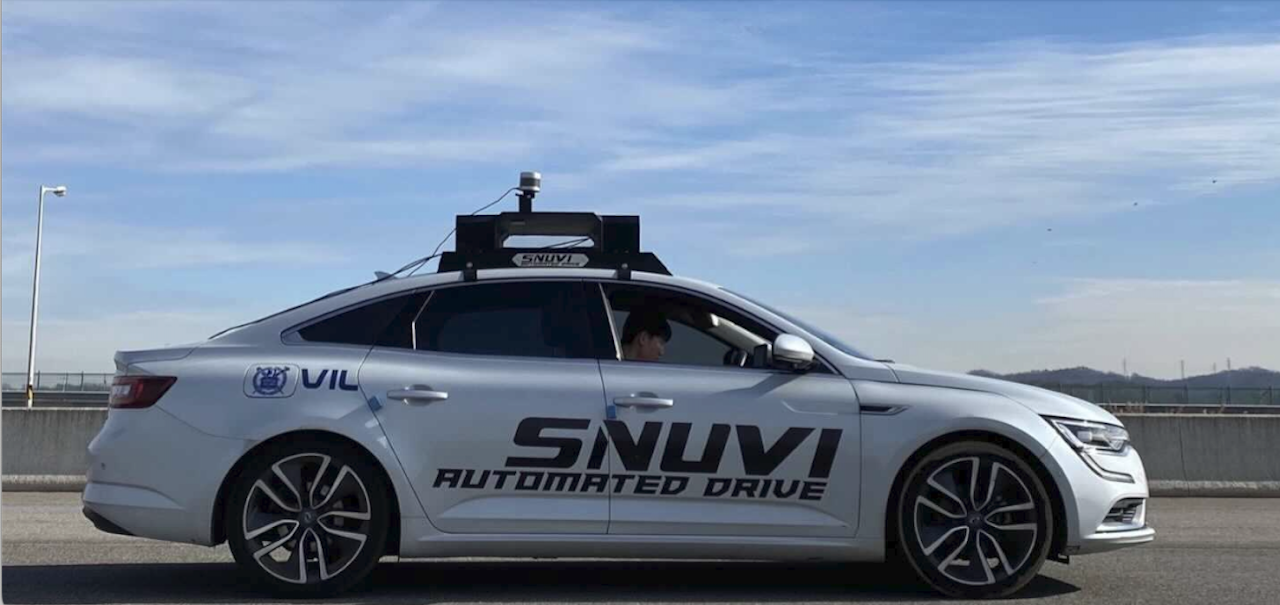
SNUVI: Autonomous Vehicle System for Urban Driving at K-City
Jul 2020 – Feb 2021
SNUVI is an autonomous vehicle developed for urban driving, integrating perception, localization, planning, and decision-making modules. As Team Leader of the overall project, I developed local path planning algorithms and participated in real-vehicle testing and system validation at K-City, a national autonomous driving testbed in South Korea. |
Work Experience |
|
ThorDrive
Research Intern | High-Level Decision-Making | Aug 2021 – Oct 2021
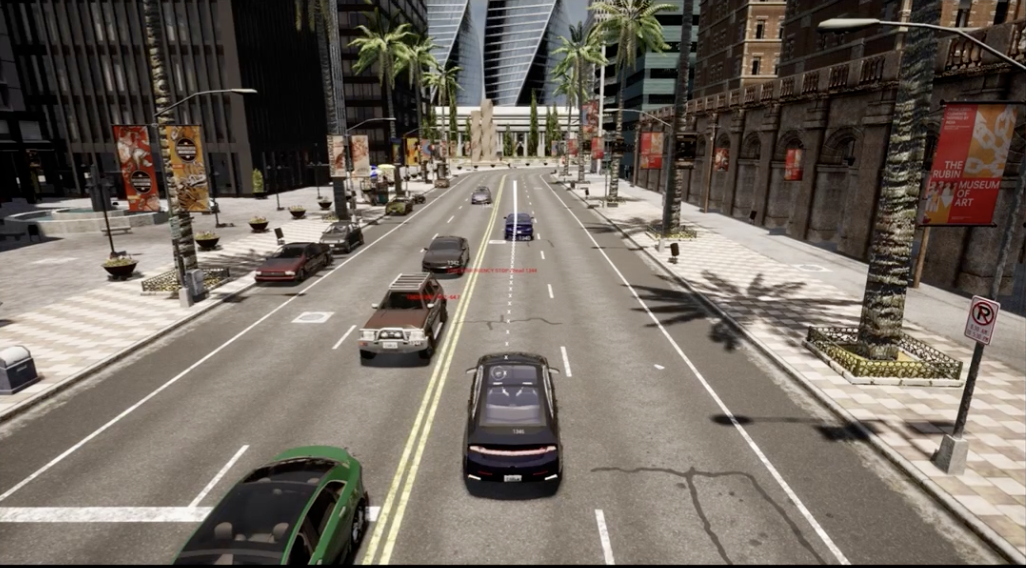
My work focused on hybrid high-level decision-making for autonomous driving, combining rule-based and reinforcement learning approaches for candidate-path selection in lane-change and detour scenarios. This work also involved constructing CARLA scenarios with illegally parked vehicles to investigate RL-based candidate-path selection. |
|
|